Physicl raises $10M to make the digital world real enough for robots
Physicl, a new venture from founder and CEO Alex de Vigan, has raised $10 million in seed funding from Inovia Capital. De Vigan previously spent a decade building nfinite, which let brands and retailers create 3D models of their goods and display them online. As transformer-based generative AI overtook that kind of work, he saw a new purpose for the team and the 3D rendering stack: “What we were super unique about doing in 3D, AI was going to replace, but something was missing in AI: its ability to understand, interact, and manipulate space and objects.”
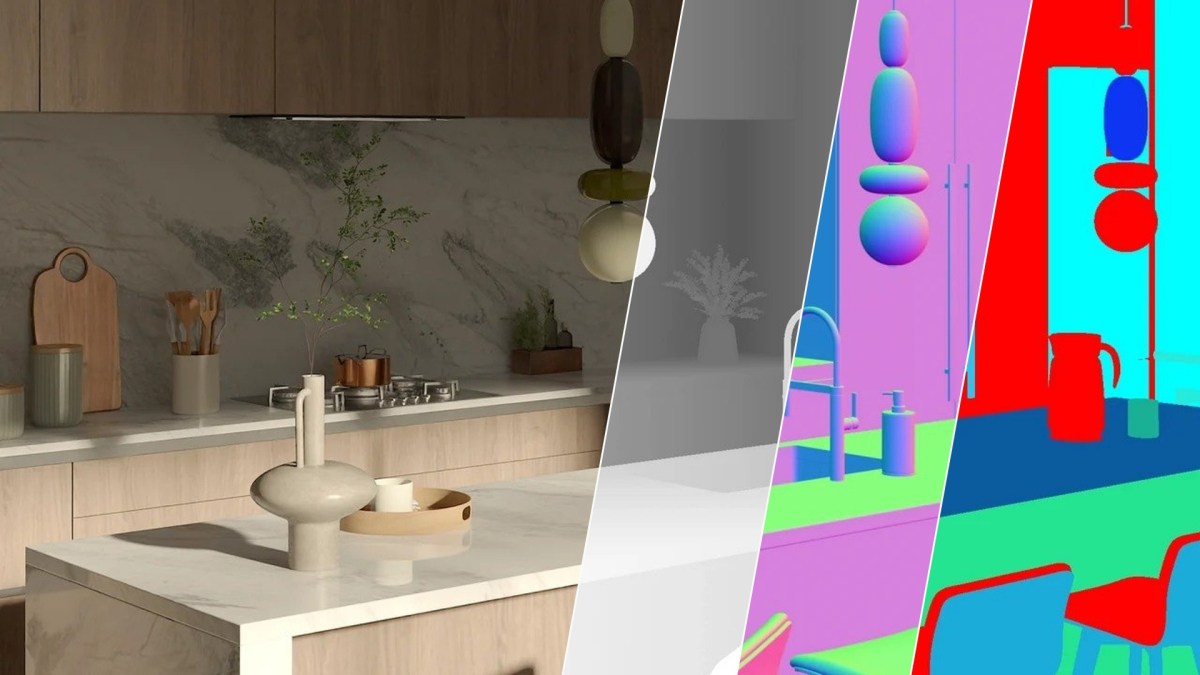
Physicl aims to help world model designers and robot builders solve thorny training problems with more realistic simulations. Physical AI researchers have been frustrated by the returns of training robots on video and the expense of gathering data through remote operations. Simulations in digital worlds are promising, but ensuring they are faithful to real-world physics has proven difficult. Physicl says its pipeline converts “unstructured, incomplete, heterogeneous real-world information into a high-fidelity physical representation… with correct geometry, materials, and physics.”
The company is releasing a product called Studio, with 10,000 3D environments and 100,000 assets representing various objects. Users can create scenes to generate synthetic data for training robots on specific edge cases—for example, helping a robot that has trouble discerning a cup on a cluttered countertop or while the cup is in shadow. Physicl plans to focus on post-training models on difficult edge cases, and acknowledges it is entering a crowded category of startups providing data and tooling to foundation model builders and robot operators. The space, de Vigan says, is “very young and blurry sometimes.”
SpAItial, a world model builder, worked with Physicl as an early customer to improve the fidelity of its products; its latest tool, Echo-3, released last week, generates 3D simulations from 2D imagery. SpAItial CEO Matthias Niessner, a professor of robotics at the Technical University of Munich, said they needed high-fidelity synthetic data and that hand-curating data is a long cycle. What Physicl offers, he said, is the ability to generate that data on the fly depending on the training state. Physicl wants to be more than a data provider, positioning itself as the tooling for ongoing synthetic data generation. De Vigan describes the underlying work as an agentic workflow, with customers potentially bringing trillions of images or millions of hours of LIDAR capture data to create high-quality 3D representations and billions of training permutations.