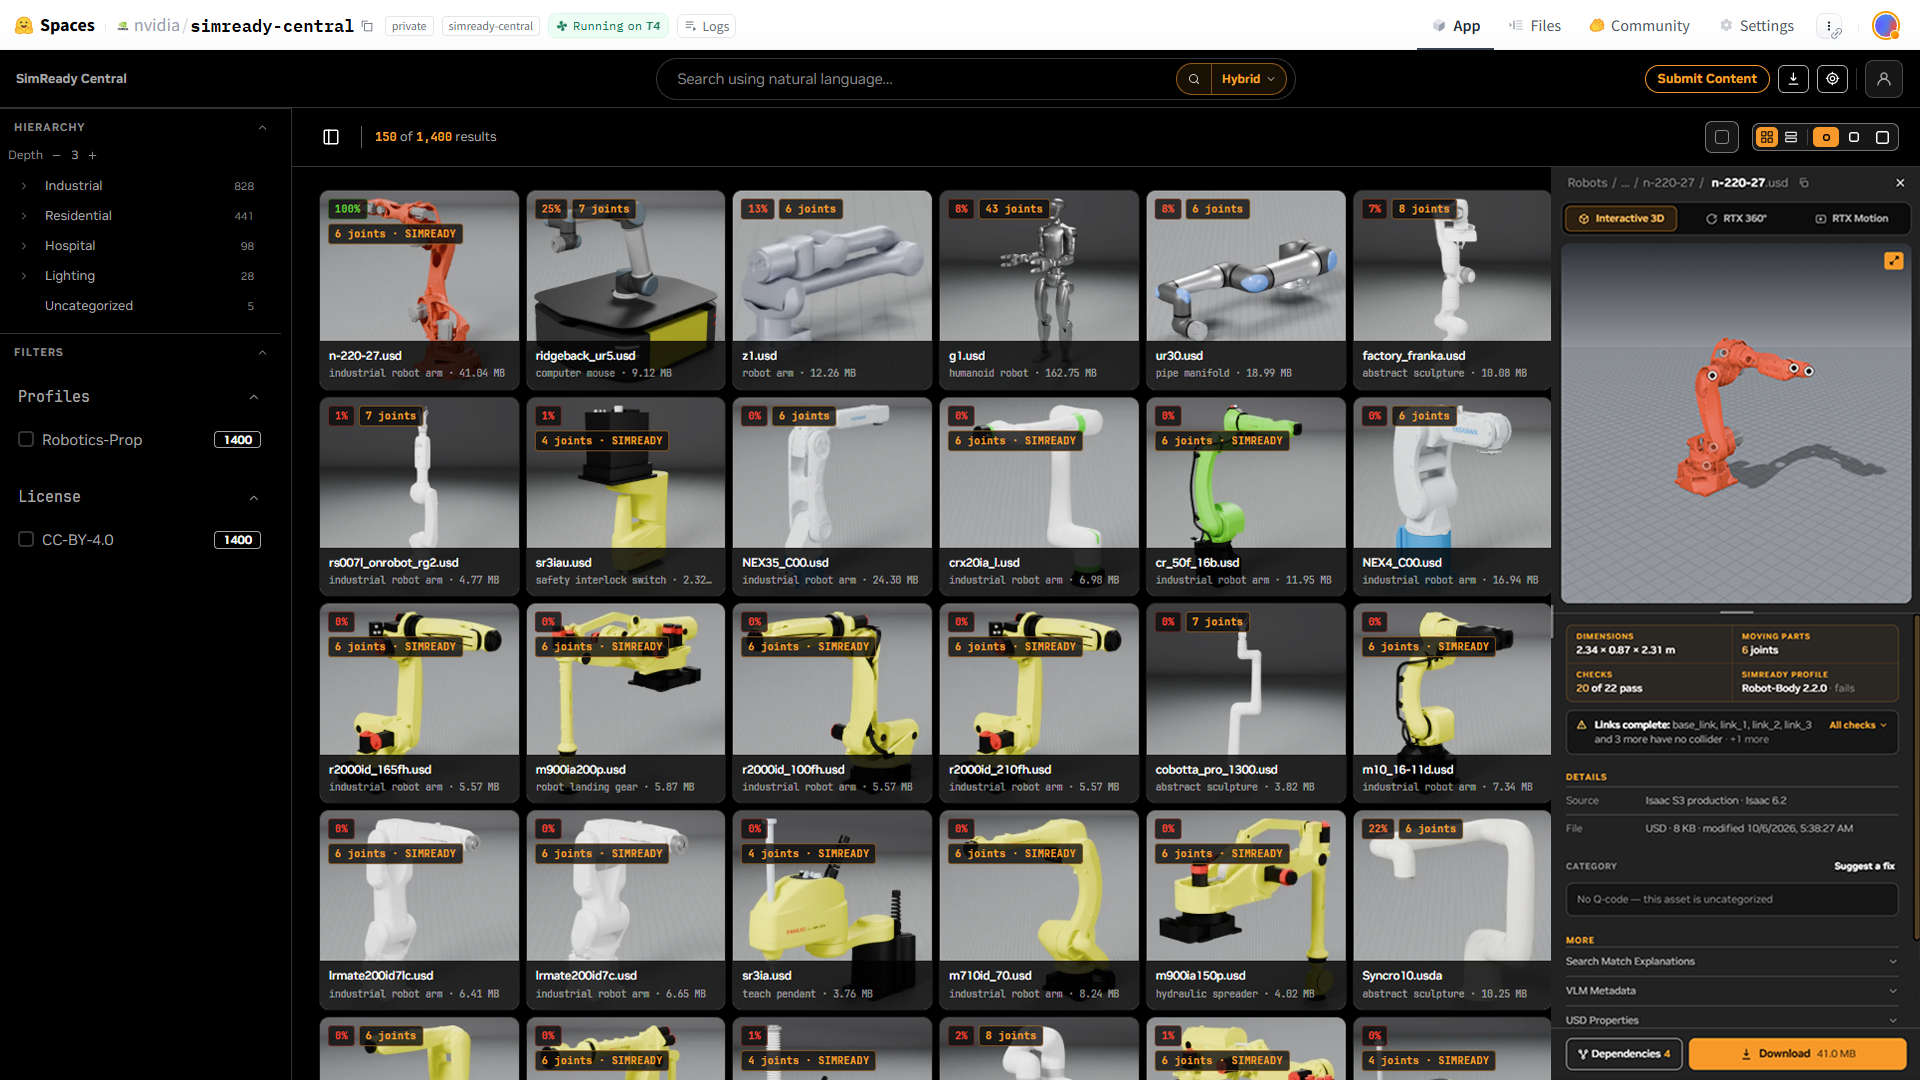
SimReady Central Library: 2,000+ Simulation-Ready OpenUSD Assets
NVIDIA has announced SimReady Central Library, an open library of more than 2,000 simulation-ready (SimReady) OpenUSD assets hosted on Hugging Face, positioned as a free, ungated starting point for physical AI training environments and AI factory digital twins. The assets span robot arms, grippers, warehouse equipment, racks, and cooling infrastructure; developers can check which capabilities each asset supports and combine assets from different suppliers into a scene.
SimReady assets are OpenUSD models prepared with simulation workflow properties beyond appearance. Depending on the use case, that can include collision geometry, mass, friction, joint structure and limits, semantic labels, and materials or sensor attributes. OpenUSD is an open, extensible framework for describing and composing 3D scenes; SimReady Foundation provides specifications, profiles, and validation tools that make simulation requirements explicit. A profile defines the logical grouping of features and capabilities an asset needs for a particular use case, and developers are advised to select assets whose profiles match their workflow.
OEMs and asset providers are the main contributors. Equipment manufacturers can prepare and validate assets against SimReady requirements, then distribute them through SimReady Central while managing their own Hugging Face datasets. The article lists Vertiv (warehouse/server racks, cooling equipment), Comau, FANUC, Franka Robotics, Robotiq, Standard Bots, Universal Robots (robot arms and grippers), Palatial with the NVIDIA Robotics 1K Dataset and articulated assets, LG Electronics (home robots plus appliances like refrigerators and dishwashers), and ForgeCAD (articulated robotics props). Contribution uses a SimReady Central submission skill to validate, package, and submit assets.
For developers, NVIDIA USD Search powers natural-language search across participating datasets and is also integrated into Hugging Face‘s platform search, letting AI agents find SimReady assets. AI-assisted authoring with frontier models like OpenAI’s GPT-6 Astra can find assets, write OpenUSD scene-building code, and create scenario variations. The post walks through two examples: a warehouse pick-and-place scenario with a FANUC robot and Robotiq gripper in Isaac Sim using PhysX, and an AI factory layout comparison with racks and cooling equipment, including overlap and aisle-clearance checks.
Suggested extensions include keeping layout and task-specific changes in separate OpenUSD layers for reuse, varying objects and placements, building application-specific tests in Isaac Lab, and connecting validated AI factory layouts to live BMS and IT telemetry. The roadmap calls for more OEM partners and community feedback on needed assets, runtimes, and integration gaps.


